Purdue Robotics Engineering · May 2027

Building robotsfor the real world.

I design, simulate, train, and deploy autonomous systems — from robot learning and navigation to fielded robots operating around real people.

  • Purdue Polytechnic Institute
  • AI & Robotics
  • Graduating May 2027
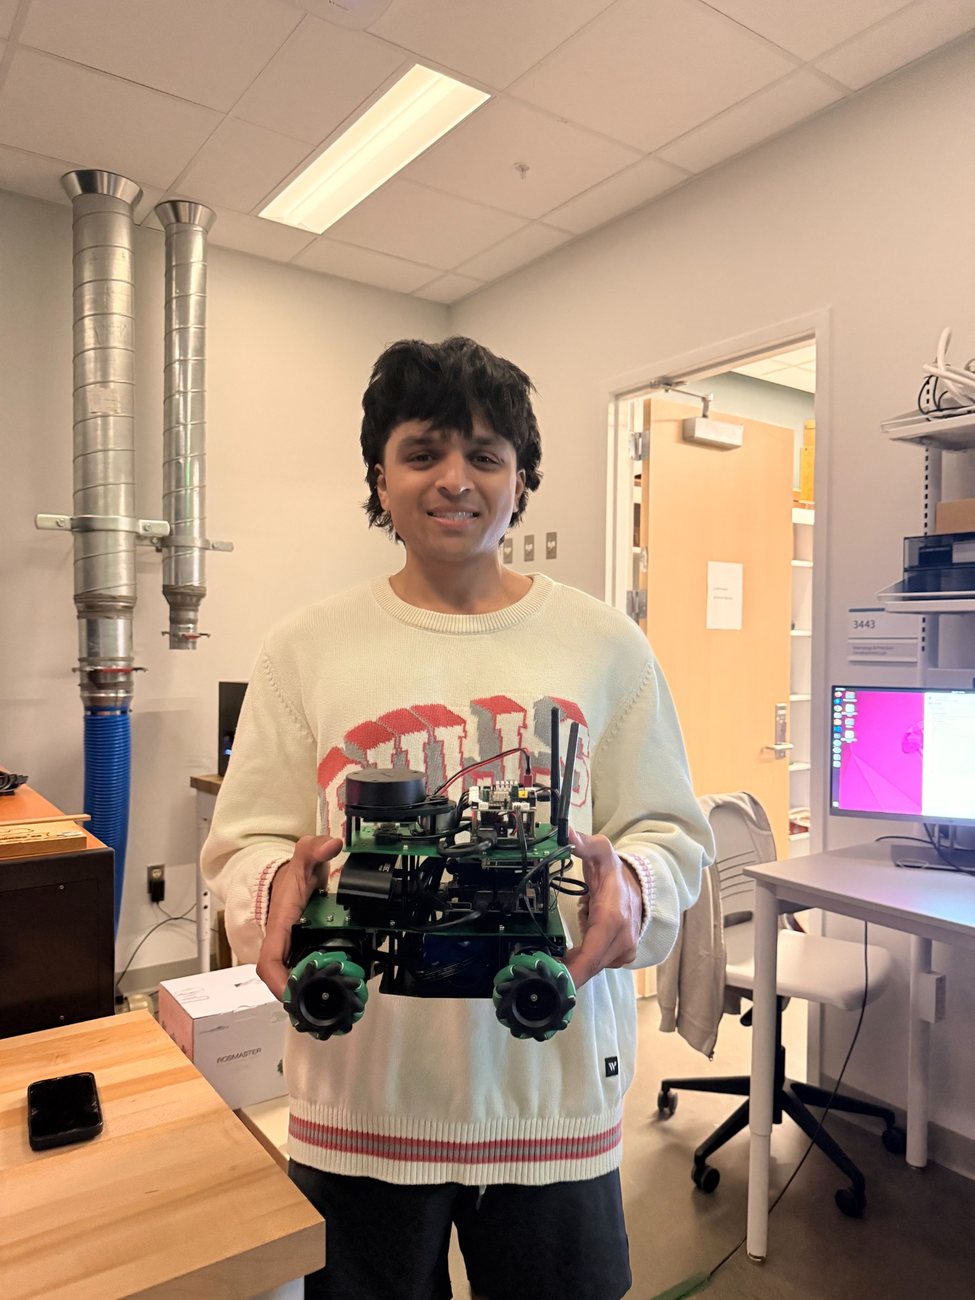
Hamza Khan holding an autonomous mobile robot in the lab

Selected work

Robotics projects.

Hands-on work across autonomy, robot learning, simulation, machine learning, embedded systems, and deployment.

01Research

CIMS Autonomous Navigation

Built and tested autonomous navigation workflows in Purdue’s CIMS Lab using ROS 2, Nav2, NVIDIA Isaac Sim, SLAM, localization, and physical robot deployment. The work focuses on closing the gap between simulation behavior and real-world navigation performance.

  • Isaac Sim
  • ROS 2
  • Nav2
Physical mobile robot testing as part of CIMS autonomous-navigation research.

01 / 02

02Robot learning

Trossen Robot Learning

Built and deployed imitation-learning pipelines on physical WidowX bimanual arms. Trained and evaluated ACT, π0.5 LoRA, and Multitask DiT policies, worked with LeRobot datasets, and debugged the full stack from dataset conversion through hardware execution.

  • LeRobot
  • ACT
  • π0.5
  • WidowX
Bimanual manipulation demo.

01 / 03

03Simulation research

CIMS Crowd Simulation

Developed a crowd-simulation demo in NVIDIA Isaac Sim inside a photogrammetry-based digital twin of Purdue’s Build @ Scale lab. Animated human agents move naturally through the environment, avoid obstacles and each other, and express distinct behaviors through HuNavSim. The scenario scales to roughly 30 people alongside autonomous mobile robots for evacuation-safety analysis.

  • Isaac Sim
  • Omniverse
  • HuNavSim
Fire-evacuation crowd simulation — 2× playback.

01 / 02

04Full-stack SaaS

Syllamake

Built Syllamake, a student productivity web app that turns uploaded syllabi and class schedules into structured calendars, assignments, exams, deadlines, and to-do views. The product supports AI-powered document parsing, editable calendar organization, recurring class schedules, progress tracking, and calendar export so students can move from a syllabus to an actionable semester plan in seconds.

  • AI Parsing
  • Calendar UI
  • Full-stack
  • SaaS
Syllamake product walkthrough — accelerated from ~76.7 seconds to ~20 seconds.

01 / 01

05Robotic systems

Panera Innovation Lab

At the Panera Innovation Lab, I developed simulation models to evaluate autonomous-system behavior before physical deployment and validated hardware-software integration through structured testing across multiple concurrent robotic subsystems. The work combined rapid prototyping, system-level debugging, and hands-on testing in an applied innovation environment.

  • Simulation
  • System Testing
  • Hardware Integration
  • Rapid Prototyping
Panera Innovation Lab — robotic system prototyping and testing.

01 / 03

06Healthcare robotics

Diligent Robotics

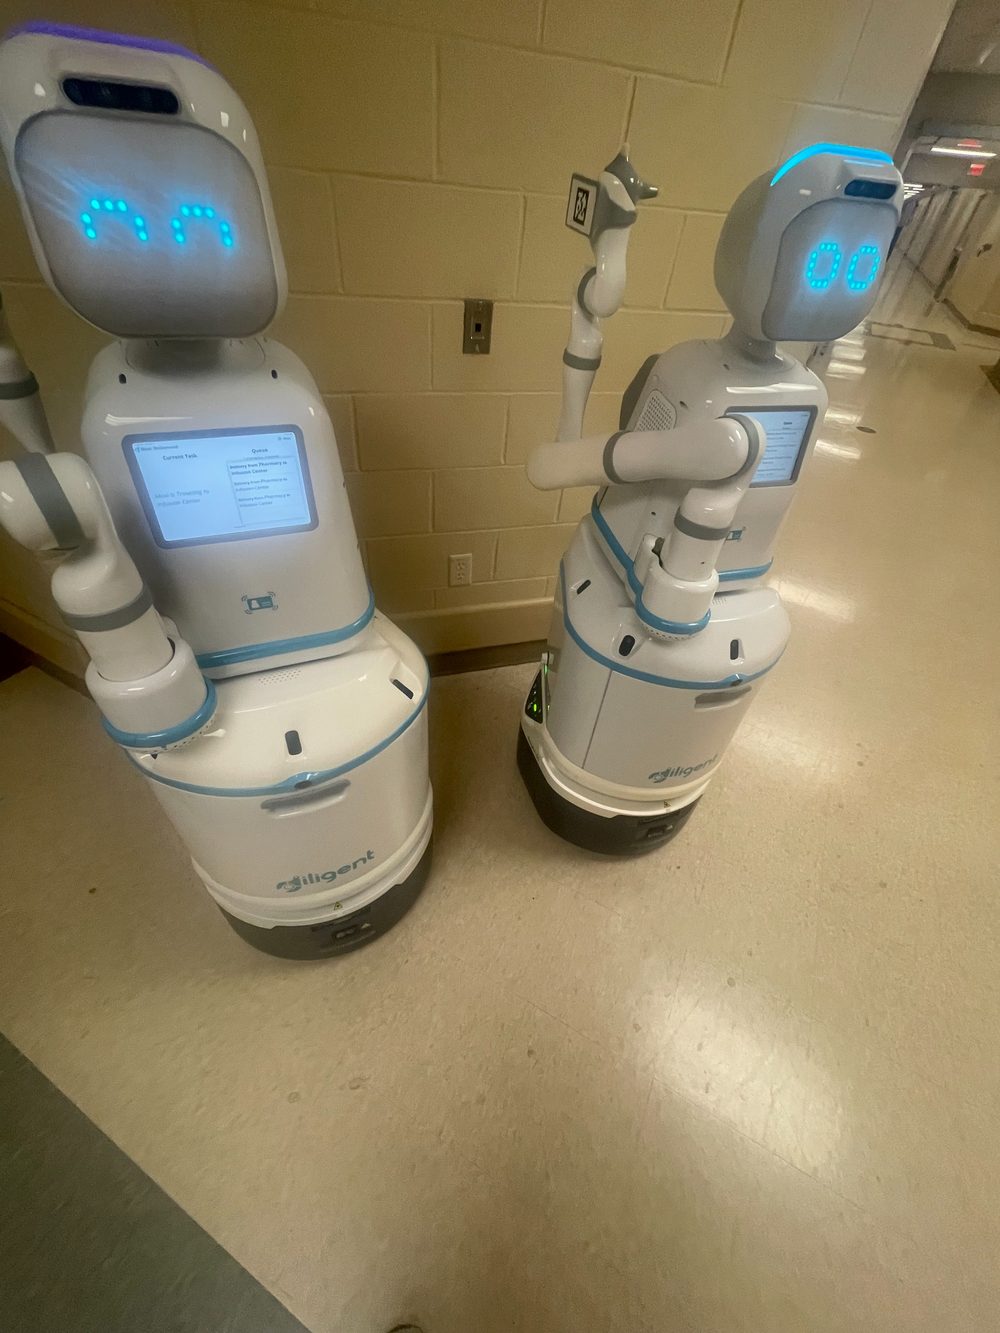
Deployed and supported Moxi, an autonomous mobile manipulation robot, in a live hospital environment. Monitored autonomous navigation and task execution, supported material-delivery workflows, and troubleshot real-world robot behavior around clinical staff and patients in a safety-critical setting.

  • Autonomous Mobile Robots
  • HRI
  • Deployment
Two Moxi hospital robots waiting in a clinical corridor
Moxi robots operating in a hospital environment.

01 / 01

07Machine learning research

Breast Cancer ML Study

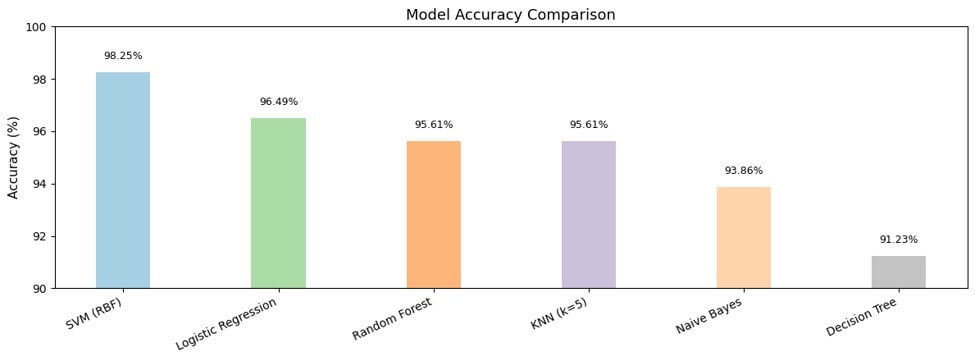
Co-authored a published machine-learning study comparing six supervised classifiers for breast cancer diagnosis using the Wisconsin Breast Cancer Diagnostic dataset. We evaluated Logistic Regression, Naive Bayes, Decision Tree, Random Forest, SVM, and KNN on 569 patient records using an 80/20 train-test split. The RBF-kernel SVM achieved the highest accuracy at 98.25%, with strong precision and recall and only two errors in the test-set confusion matrix.

  • SVM
  • Scikit-learn
  • WDBC
  • Model Evaluation
Bar chart comparing accuracy across six supervised classifiers
Model accuracy comparison across six supervised classifiers; RBF SVM achieved 98.25%.

01 / 01

08Embedded systems

Line Follower Robot

Built and tuned a mobile robot that follows a defined path using reflectance sensing and motor control. The project combined an Arduino Mega, QTR-8RC sensor array, TB6612FNG motor driver, drivetrain integration, and iterative control tuning.

  • Arduino Mega
  • QTR-8RC
  • TB6612FNG
  • C++
Line-following robot hardware test.

01 / 01

09Embedded · PCB design

LED Ring Light PCB

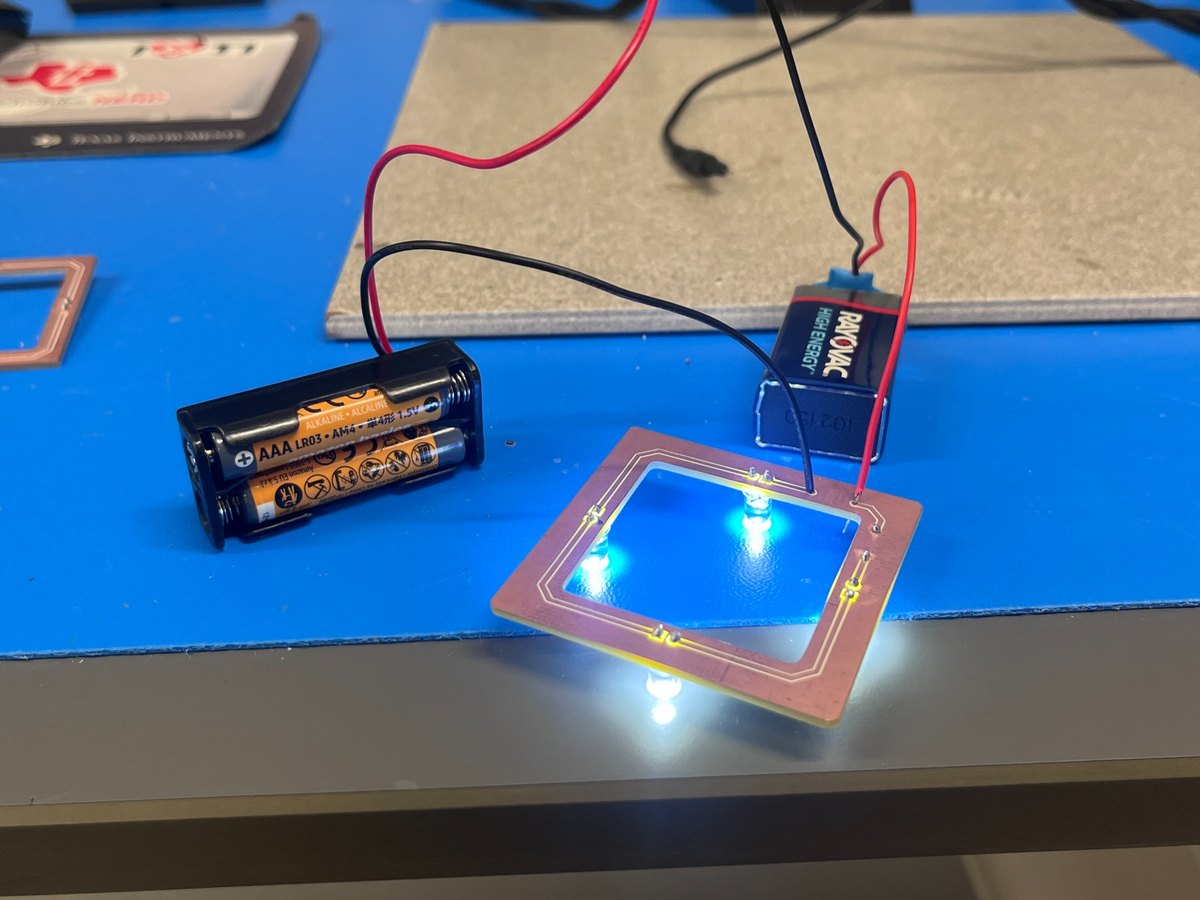
Designed and built a custom LED ring-light PCB in KiCad for close-up phone photography. The square board has a center cutout so a phone lens can shoot directly through the light source while four white LEDs illuminate the subject evenly from each side. I created the schematic and PCB layout, selected the components, soldered and tested the board, and mounted it inside a light-box setup to validate the final illumination.

  • KiCad
  • PCB Design
  • Circuit Design
  • Prototyping
Finished LED ring light PCB powered on at the bench
Finished board, powered and working.

01 / 02

  • 10Autonomous robotics

    EcoRobotics

    Autonomous outdoor trash-collection robot I founded.

    • ROS 2
    • Nav2
    • SLAM
  • 11ROS 2 capstone

    Gazebo Autonomous Navigation

    Indoor autonomous navigation with AprilTag localization.

    • ROS 2
    • Gazebo
    • pupil-apriltags
  • 12Electromechanical

    IRoMan

    Motorized 3D-printed helmet with servo actuation and lighting.

    • Fusion 360
    • Arduino UNO
    • Servos
    • 3D Printing

Experience

Hands-on work across the stack.

Research, internships, leadership, and deployment experience across real robotics systems.

  1. 2026 — Present

    Research Assistant · CIMS Lab, Purdue University

    Digital twins, autonomous navigation, ROS 2/Nav2, sim-to-real calibration, and safety-focused robotics research.

  2. Summer 2026

    Robotics Intern · Trossen Robotics

    Robot learning, LeRobot, bimanual manipulation, policy training, evaluation, and physical deployment.

  3. Summer 2025

    Mechanical Engineering Intern · Panera Innovation Lab

    Simulation, rapid prototyping, robotic-system testing, and hardware-software integration across applied automation projects.

  4. 2025 — Present

    Research Assistant · Purdue University

    Machine-learning model validation and perception/anomaly-detection work for robotics data.

  5. 2025 — Present

    Founder & President · EcoRobotics

    Founded and lead an autonomous robotics organization spanning software, controls, hardware, perception, and operations.

  6. Clinical role

    Clinical Robotics Associate · Diligent Robotics

    Supported Moxi deployment, autonomous task execution, and real-world operation in a hospital environment.

About

From simulation to deployment.

I'm a hands-on robotics engineer who works across robot learning, autonomy, simulation, embedded systems, and deployment. I like being close to the hardware — building, testing, debugging, and iterating until a system works outside the lab demo. My focus is taking robotics from simulation and software into reliable physical systems.

01 · Simulate
Isaac Sim / Gazebo
02 · Learn
LeRobot / ACT / π0.5
03 · Navigate
ROS 2 / Nav2 / SLAM
04 · Deploy
Physical robots / HRI

In the lab

Hardware integration — build, wire, debug, iterate.

01 / 02

Real work, real hardware. I spend as much time testing and debugging physical systems as I do writing code or working in simulation.